Research in practice

Portfolio

Robot design, analytical modeling, and control — brought together through simulation and experiments.

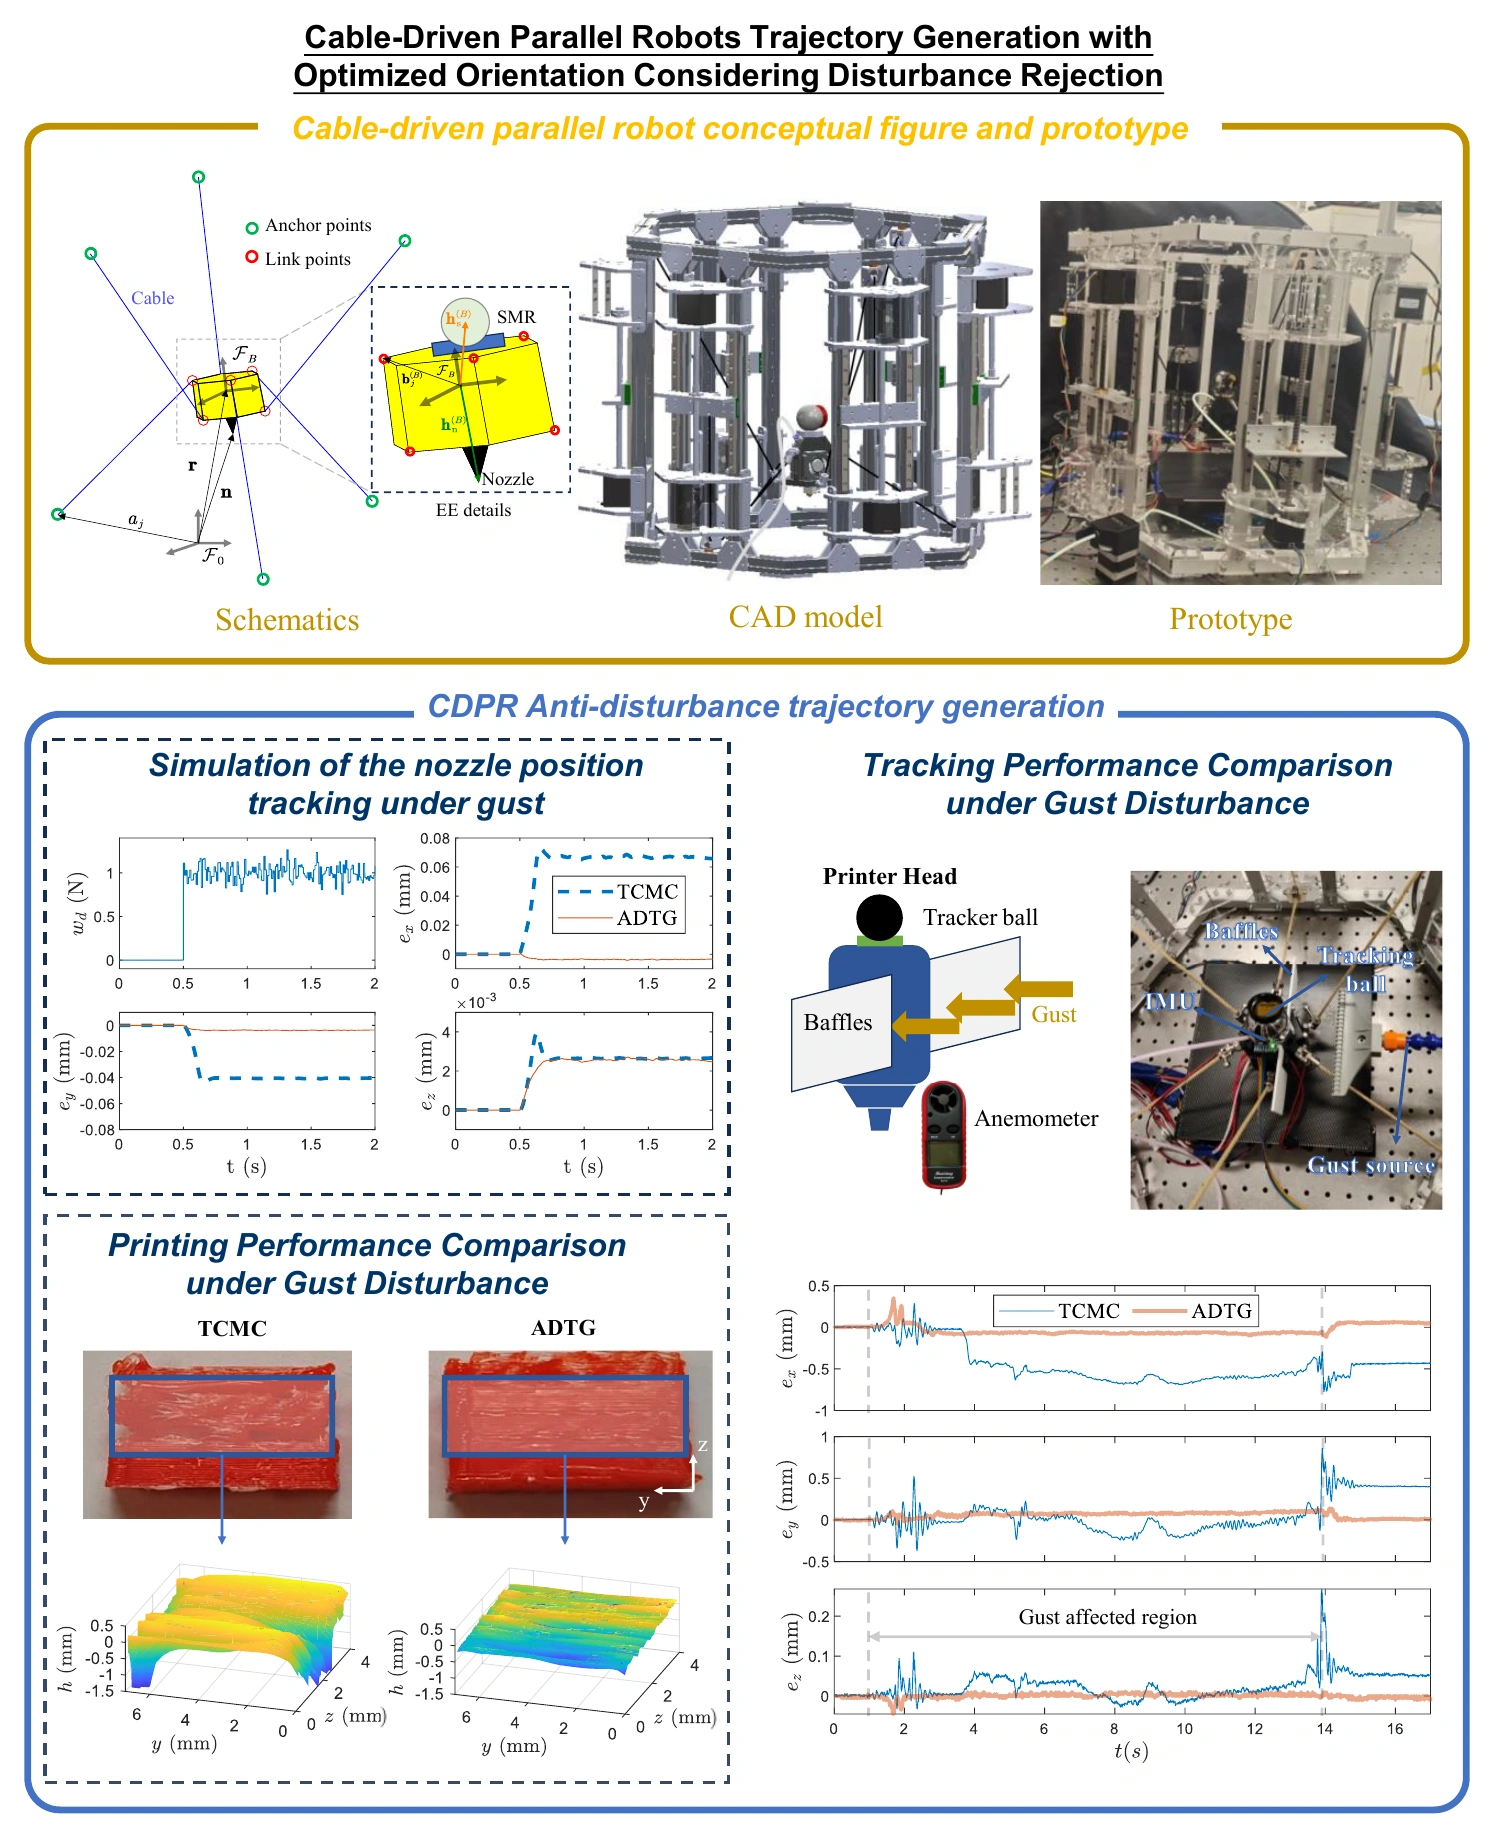
CDPR graphical abstract: robot schematics, CAD model, prototype, and tracking and printing comparisons under gust disturbances

01 / Cable-driven robotics

Cable-driven parallel robot

Robot modeling, error compensation, and orientation optimization for accurate printing under wind disturbances. Validated on a 6-DOF prototype through simulation, laser tracking, and printing experiments.
6-DOF prototypeTrajectory optimizationExperimental validation
Explore the CDPR project →

02 / Project

Coming soon

A new project will be added here.

03 / Project

Coming soon

A new project will be added here.