About me

I work on robot modeling, motion control, and robotic inspection. My experience combines mechanism design, analytical modeling, trajectory optimization, and hands-on implementation — from simulation and embedded control to physical prototypes and experimental validation.

My research at the Hong Kong University of Science and Technology is advised by Prof. Molong Duan in the Manufacturing and Aerospace Automation Lab. I have worked on cable-driven parallel robots, mobile robot localization, and additive manufacturing systems.

Career interests: Robotics R&D · Motion control · Autonomous systems engineering

Engineering skills

View CV →
Modeling & control
Robot kinematics and dynamics, system identification, trajectory optimization, and disturbance compensation. MATLAB / Simulink.
Robot development
Mechanism design, embedded implementation, sensor integration, and experimental validation. C/C++, Python, STM32, SolidWorks, and ANSYS.
Mobile robotics
LiDAR and RGB-D localization, surface feature tracking, and inspection. Simulation and development with Gazebo and Linux.

Featured project

All projects →
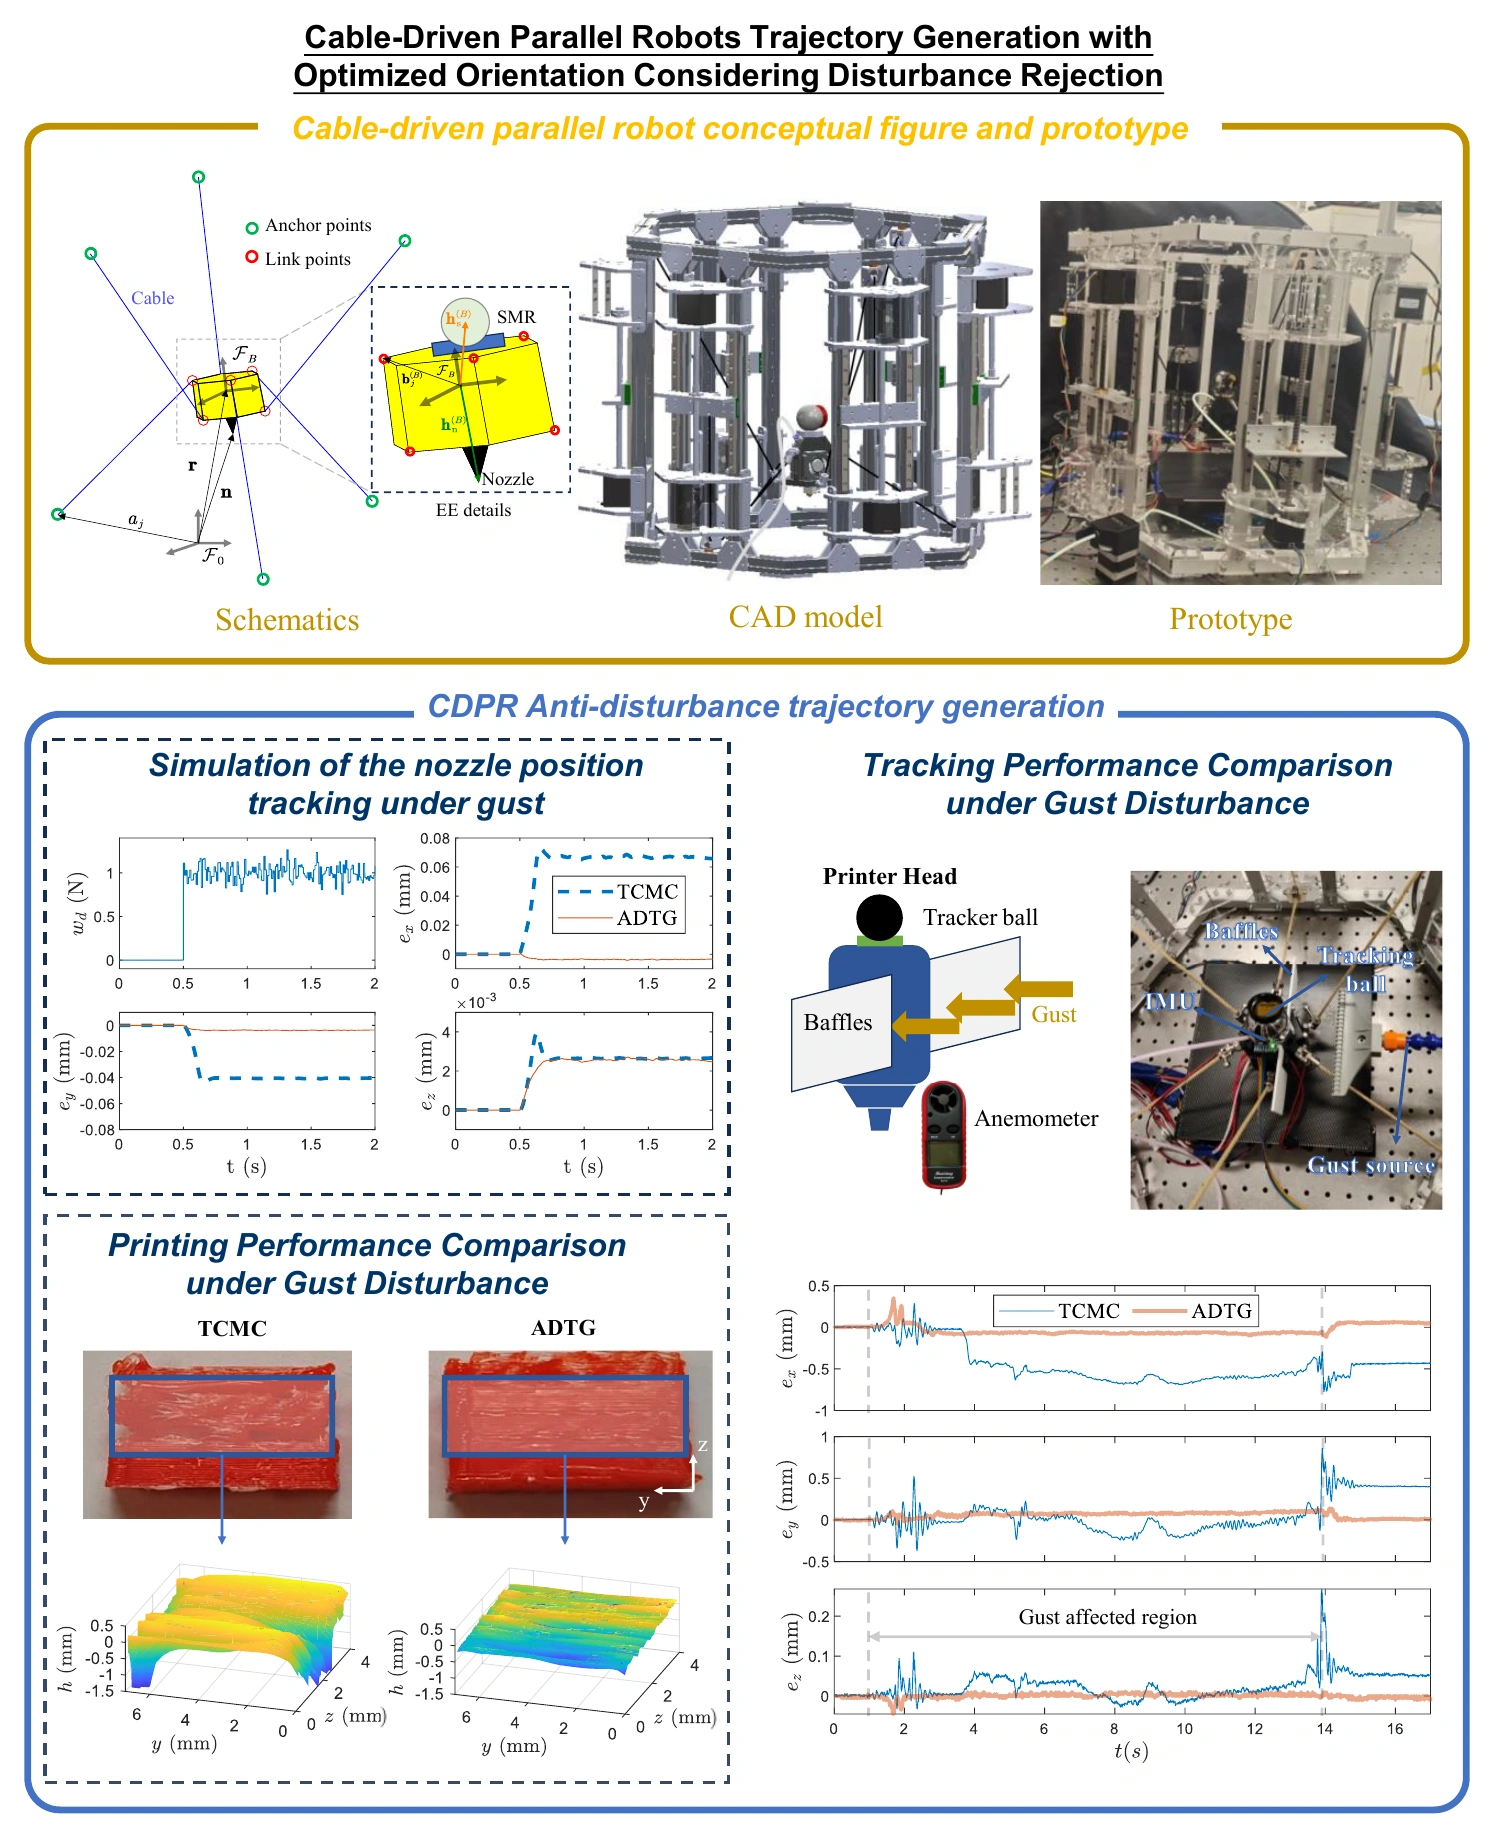
CDPR graphical abstract: robot schematics, CAD model, prototype, and tracking and printing comparisons under gust disturbances

01 / Cable-driven robotics

Cable-driven parallel robot

Robot modeling, error compensation, and orientation optimization for accurate printing under wind disturbances. Validated on a 6-DOF prototype through simulation, laser tracking, and printing experiments.
6-DOF prototypeTrajectory optimizationExperimental validation
Explore the CDPR project →

Latest updates

All publications →
  • Co-authored work on sensorless contact force estimation appears in Control Engineering Practice (online article; November 2026 issue). Read paper ↗

  • Our work on mobile robot inspection of building plenum spaces is published in Automation in Construction. Read paper ↗

  • Our CDPR study on orientation optimization for disturbance rejection is published in Mechanism and Machine Theory. Read paper ↗

Selected publications

Complete list →